
From the Hugging Face Hub to robot hardware with Strands Agents and LeRobot
AI Summary
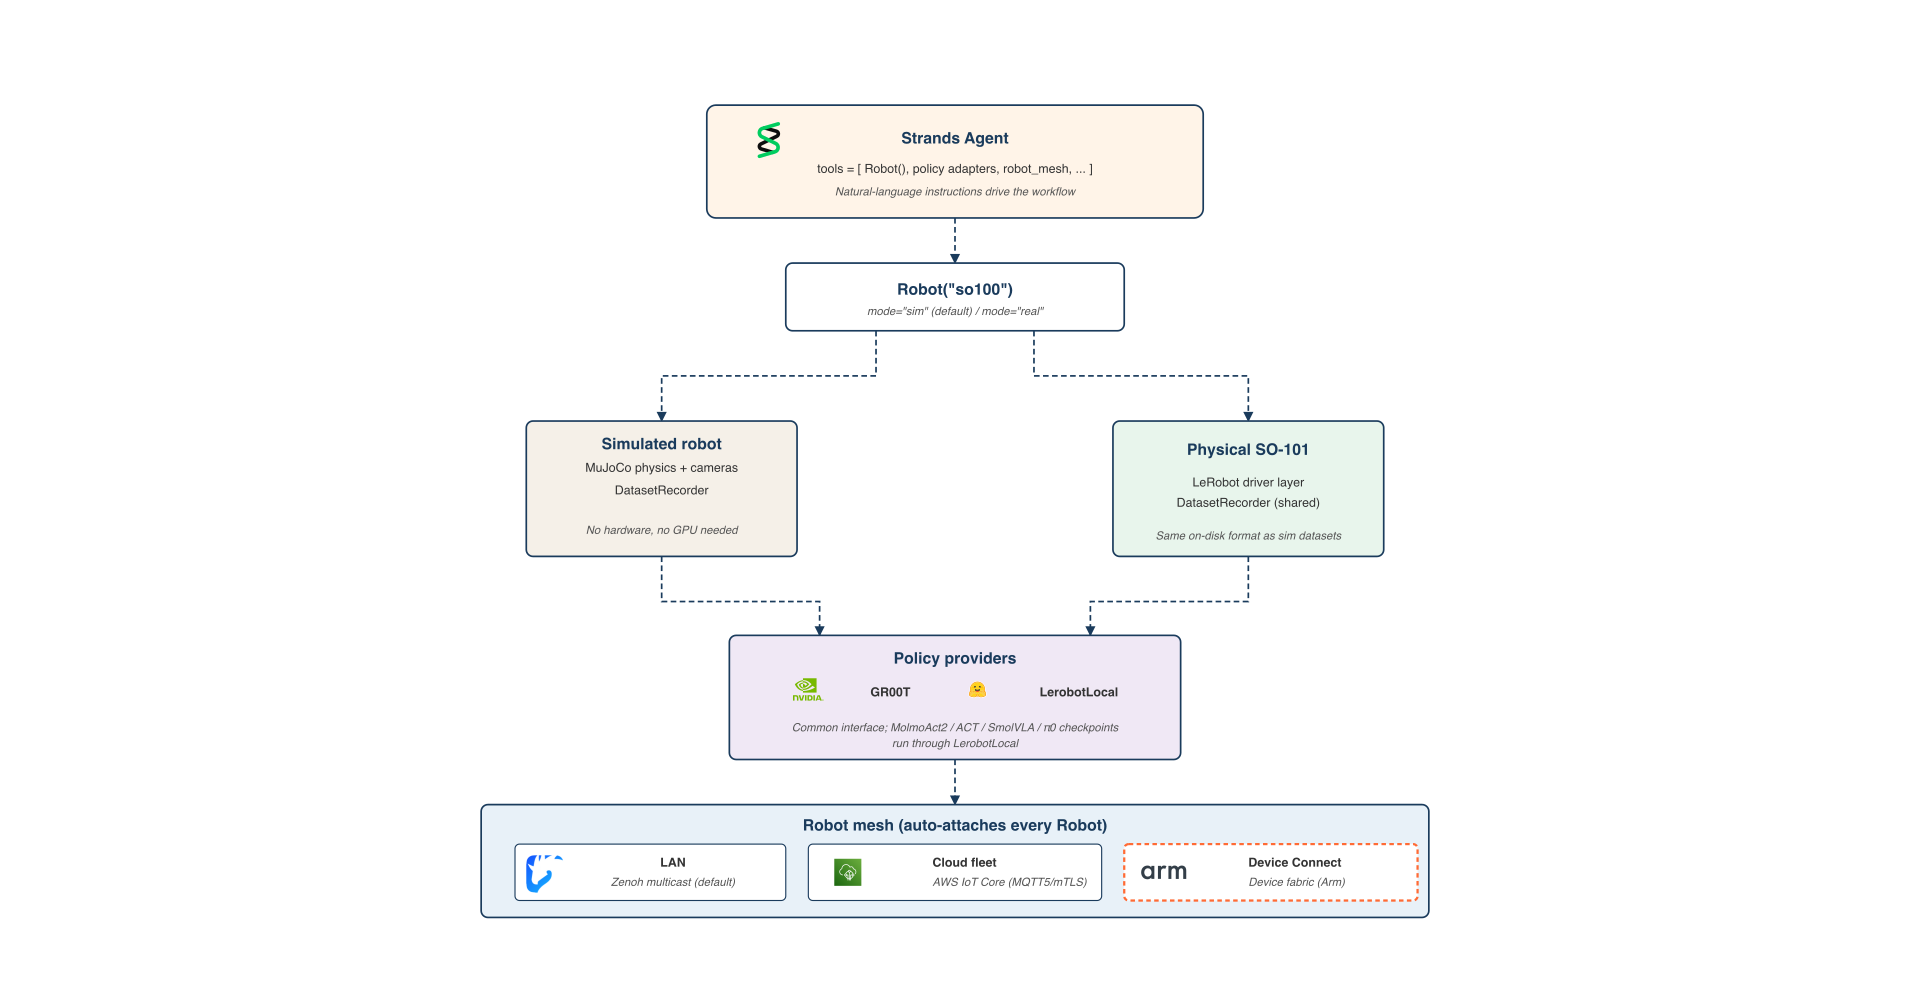
This article walks through the integration of AWS Strands Robots SDK with the LeRobot framework, connecting LLM agents to physical robot hardware and simulations. It demonstrates a unified agent loop that uses shared LeRobotDataset formats for both MuJoCo simulation and physical SO-101 robots. Developers can swap policies like GR00T, ACT, SmolVLA, and MolmoAct2 using string identifiers. The guide covers recording demonstrations, executing policy inference locally or remotely via a policy server, deploying identical agent code to hardware by changing a single keyword argument, and coordinating multi-robot fleets using a Zenoh peer mesh with built-in human-in-the-loop approvals.
Why it matters
By unifying simulation and real-world robot data formats under standard LeRobot datasets, this integration eliminates custom conversion layers and bridges the gap between generative AI agents and physical robotic hardware. It simplifies multi-tool robotics workflows into a cohesive agentic architecture that scales from a laptop simulation to multi-robot hardware fleets.
Conversation 0
Be the first to share your perspective.